

Unitree
Unitree B2 series robot dog
Unitree B2 series robot dog
excl. VAT
Leasing enquiry
Couldn't load pickup availability
Downloads & Documents
Downloads & Documents
Product Safety Information
Product Safety Information
Hangzhou YuShu Technology Co., Ltd.
https://www.unitree.com/
sales_zty@unitree.com
Building 1, No. 88 Dongliu Road 88
Room 306, Hangzhou
China

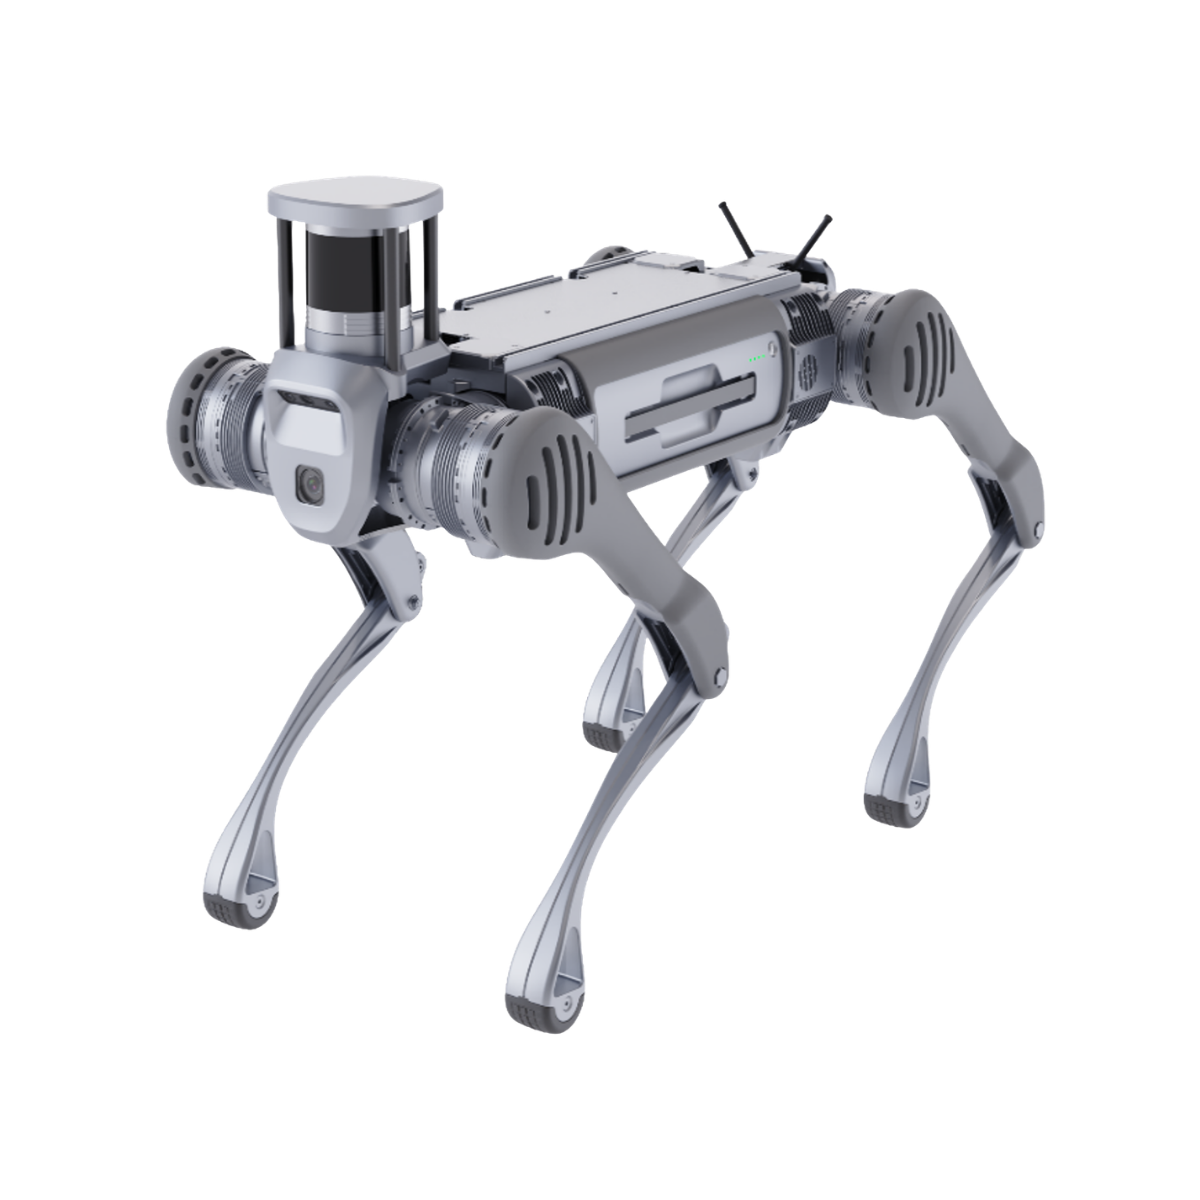
Unitree B2 versions


Product Specification
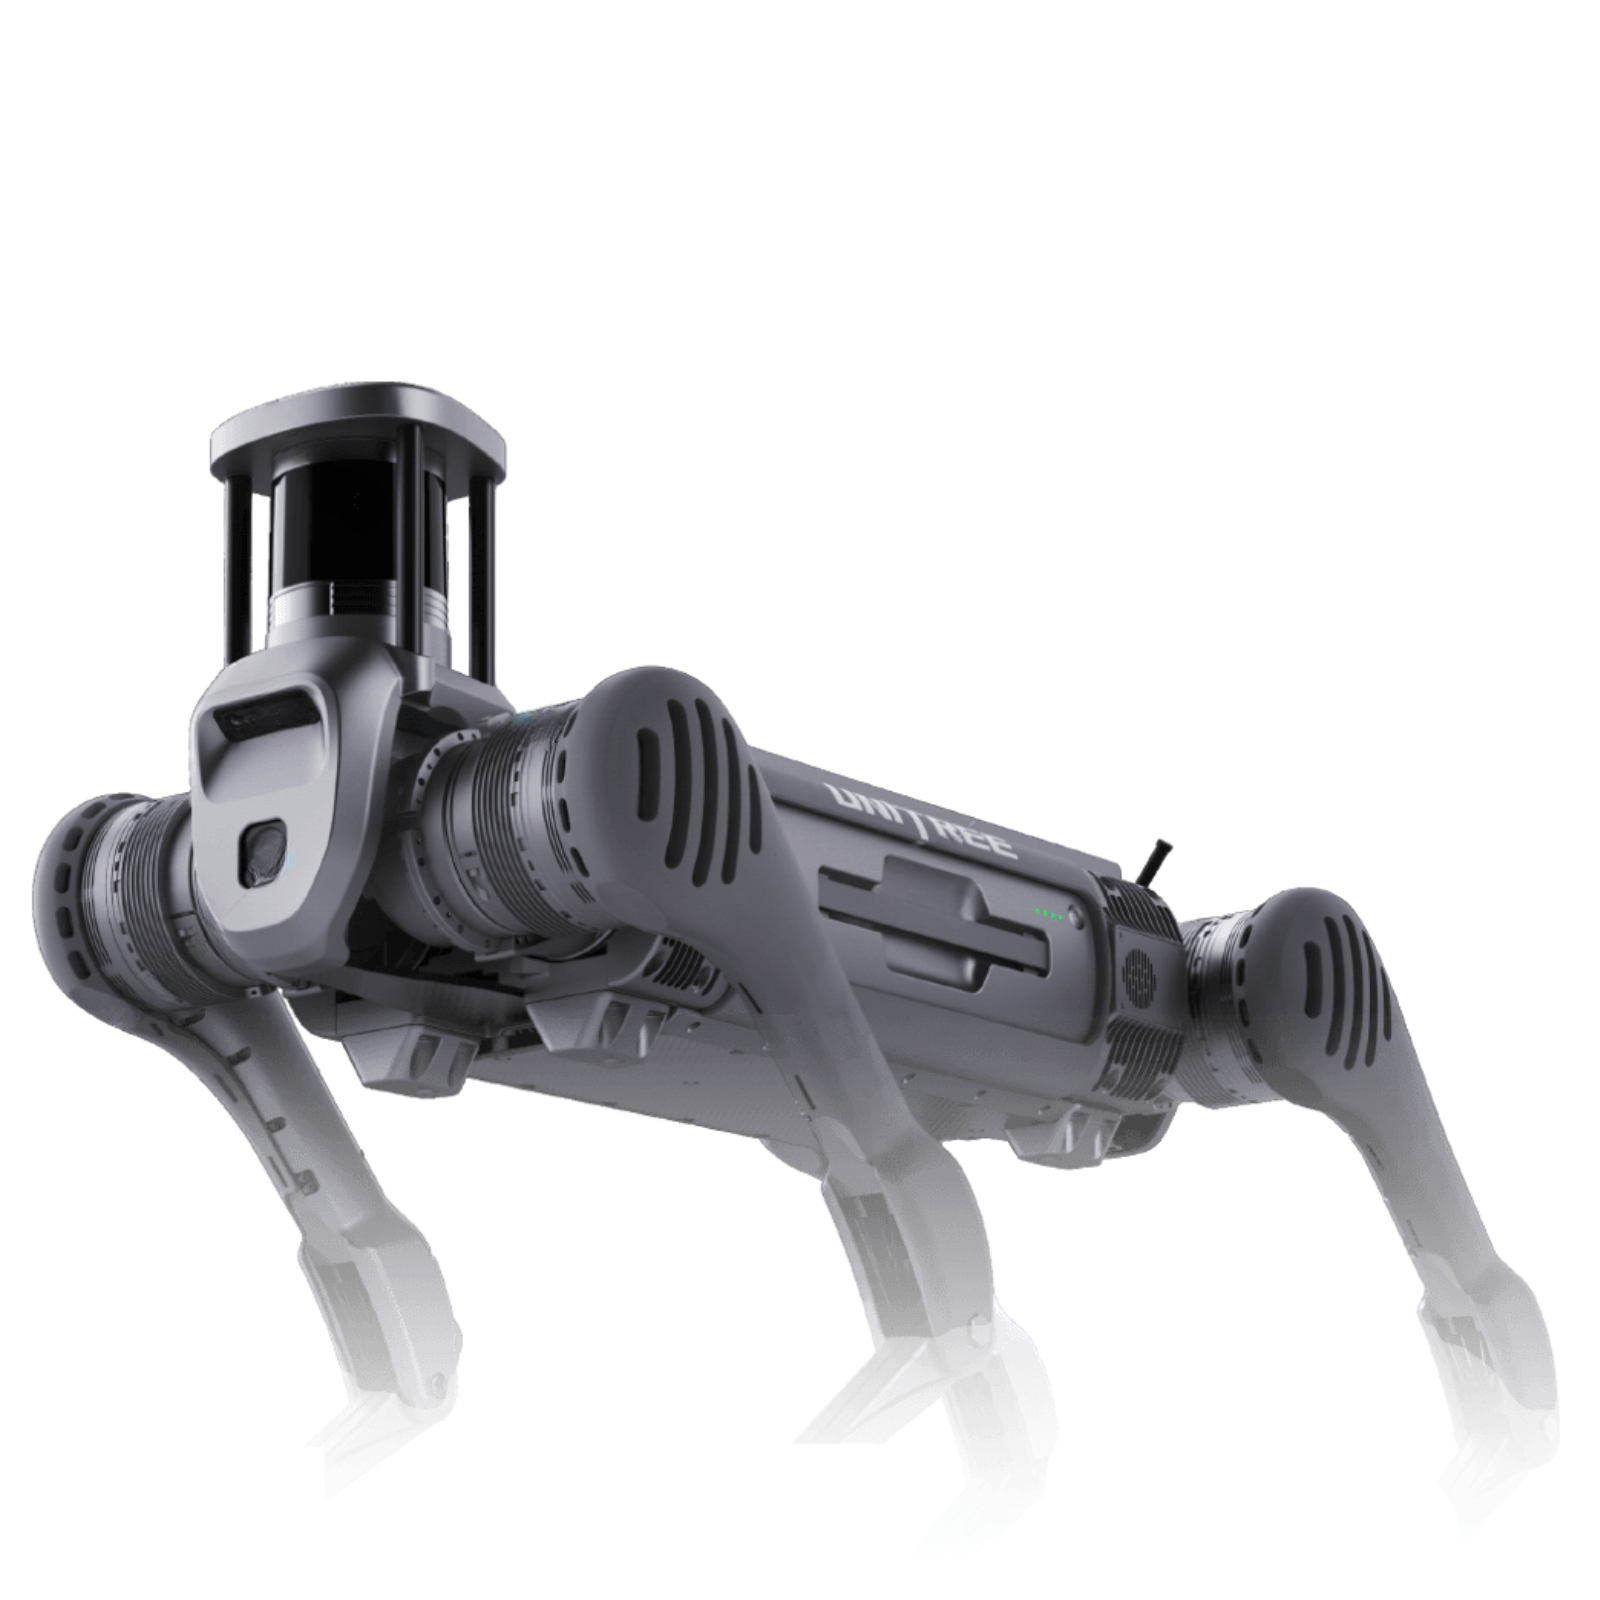
Unitree B2
Dimensions: 540 × 440 × 617 mm
Weight: 53 kg
Cleaning width: 330 mm
Gradient performance (cleaning): 5.2 %
Max. travel speed: 0.8 m/s
Minimum passage width: 600 mm
Minimum turning radius: 750 mm
Battery: 40 Ah LiFePO₄ (24 V)
Runtime: 4 – 4.5 h
Charging time: approx. 2 h
Sensors: 2× LiDAR & 1 camera
Unitree B2 Plus
Dimensions: 540 × 440 × 617 mm
Weight: 53 kg
Cleaning width: 330 mm
Gradability (cleaning): 5.2%
Max. travel speed: 0.8 m/s
Minimum passage width: 600 mm
Minimum turning radius: 750 mm
Battery: 40 Ah LiFePO₄ (24 V)
Runtime: 4 – 4.5 h
Charging time: approx. 2 h
Sensors: 3D LiDAR (advanced detection), 1 camera
Computing module (optional): NVIDIA Jetson Orin NX (100 TOPS)
Intelligent mobility with AI support
The Unitree B2 impresses with advanced 3D LiDAR sensors and a depth camera, which enable precise real-time environmental perception. Its powerful joint actuators ensure stable, fluid movement on any terrain. With the optional Jetson Orin NX (100 TOPS), the B2 becomes an ideal platform for AI navigation, research, and industrial inspection.
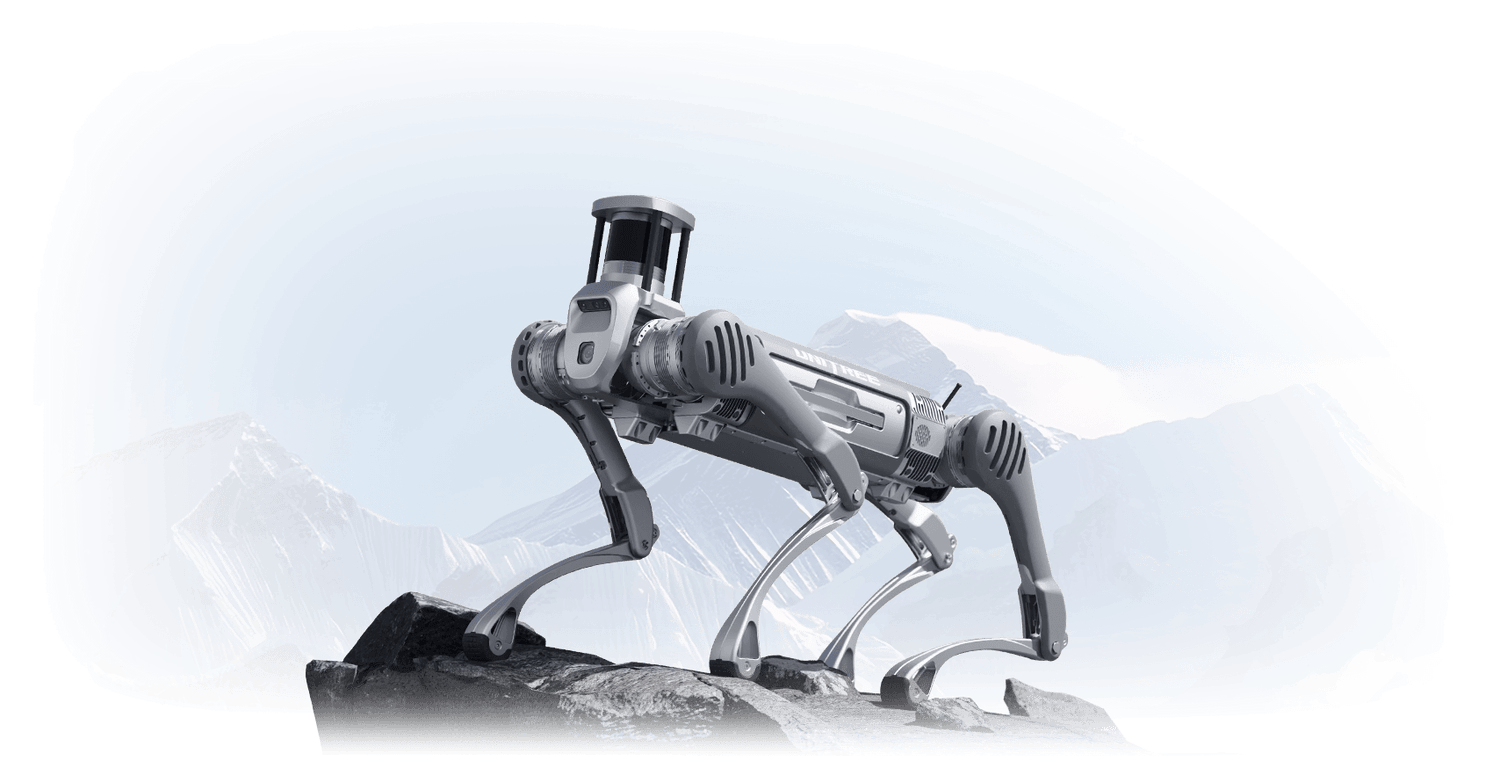
Autonomous Navigation & Environmental Perception
The Unitree B2 uses advanced 3D environmental sensing for stable and precise navigation – whether in the laboratory, outdoors, or in an industrial setting. Its integrated SLAM system creates real-time maps, detects obstacles, and continuously optimizes its movement route. With the optional Hesai XT16 or Mid-360 LiDAR, the B2 achieves even greater detail and range – ideal for research, inspection, and autonomous robotics applications.
Advanced Research & Secondary Development
The Unitree B2 is more than just a mobile robot – it serves as an open platform for research, robotics development, and AI integration. Through SDKs, ROS interfaces, and API access, custom sensors, controllers, and motion logic can be integrated directly into the existing architecture. With its modular design and expansion capabilities – such as sensor racks, tool mounts, or computing modules – the B2 is ideally suited for robotics prototyping, AI training, and simulation in scientific and industrial applications.
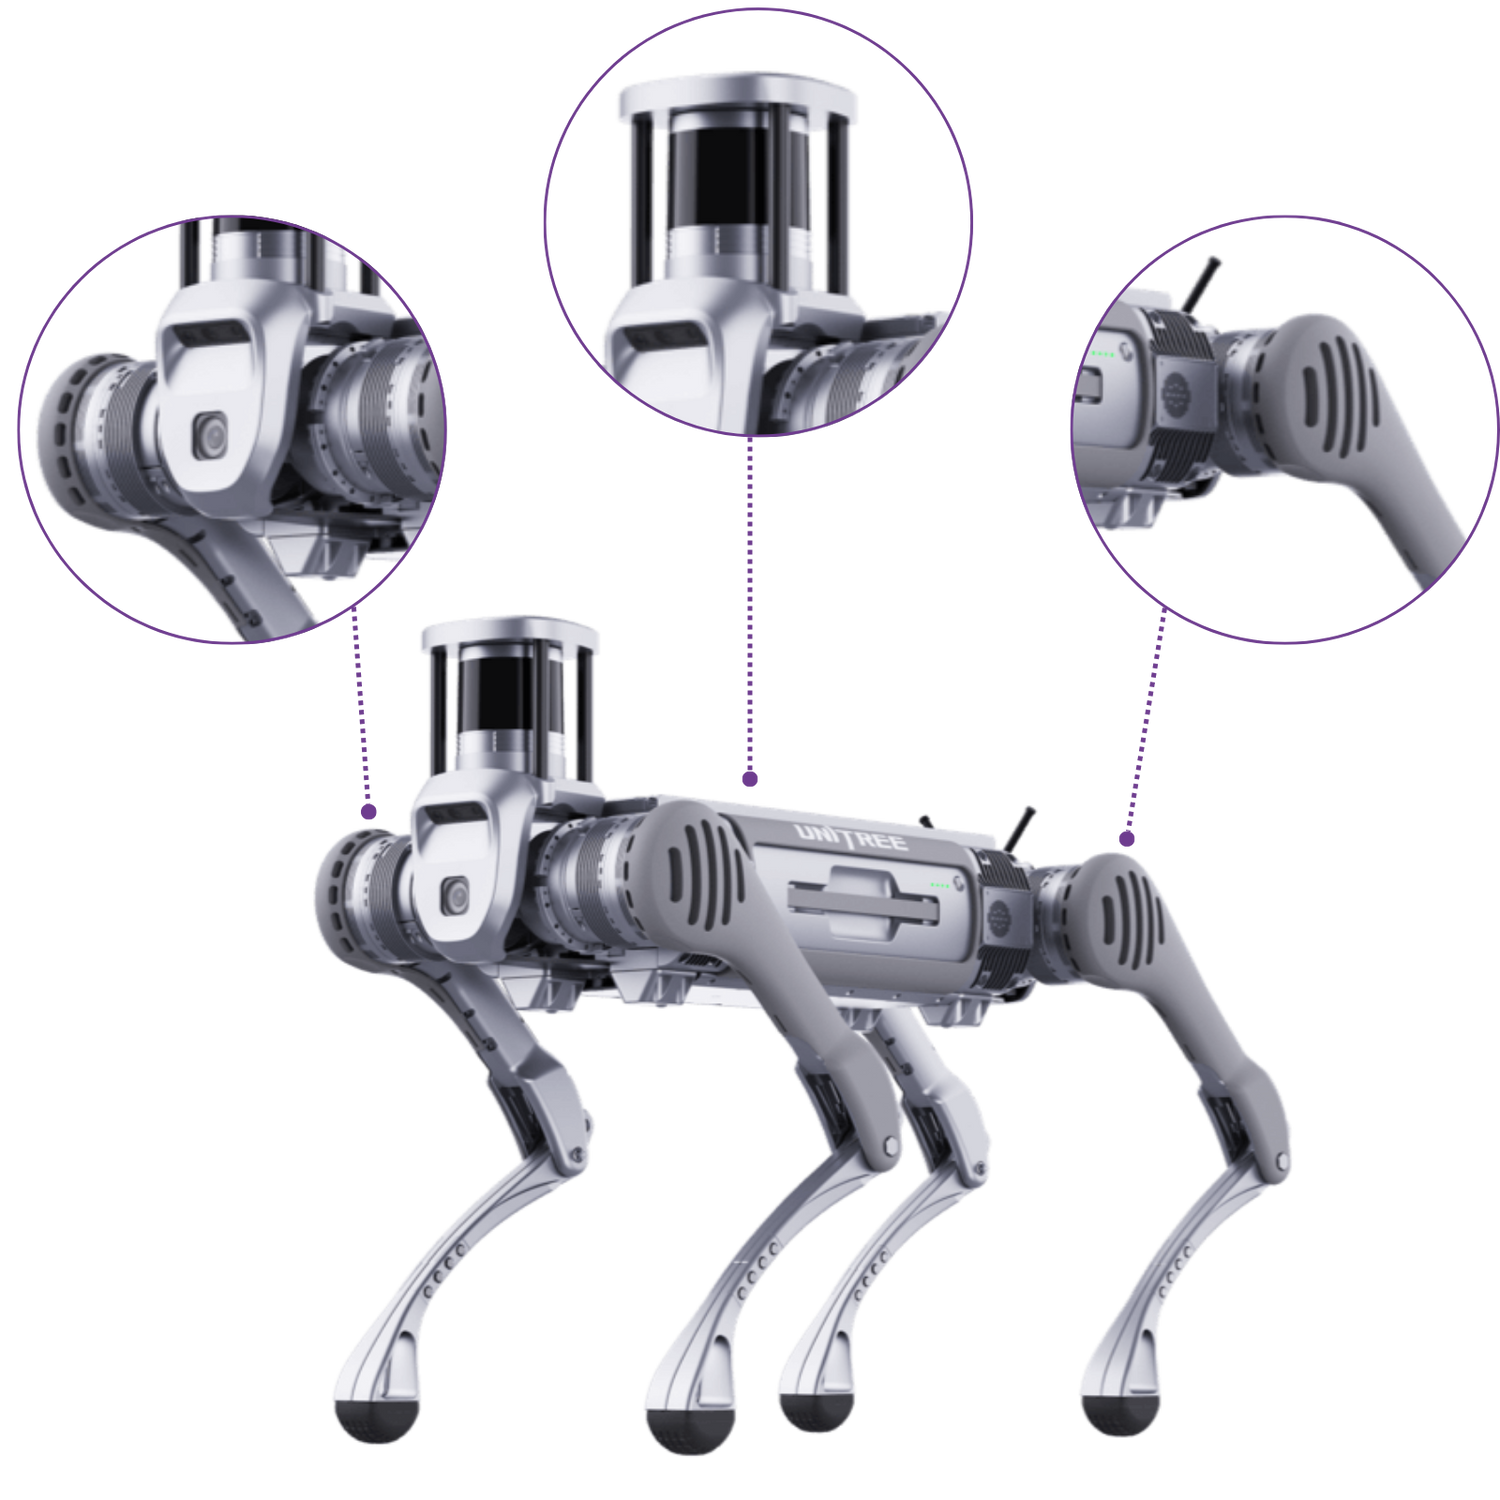
Precise. Intelligent. Autonomous.
The Unitree B2 combines powerful 3D LiDAR navigation with precise motion control and robust mechanics. Thanks to highly advanced sensor fusion, it reacts to its environment in real-time and maintains its balance even on uneven terrain. With its stable quadruped architecture, high-performance joint actuators, and optional AI computing unit (Jetson Orin NX), the B2 offers maximum efficiency and adaptability for research, industry, and autonomous robotic systems.
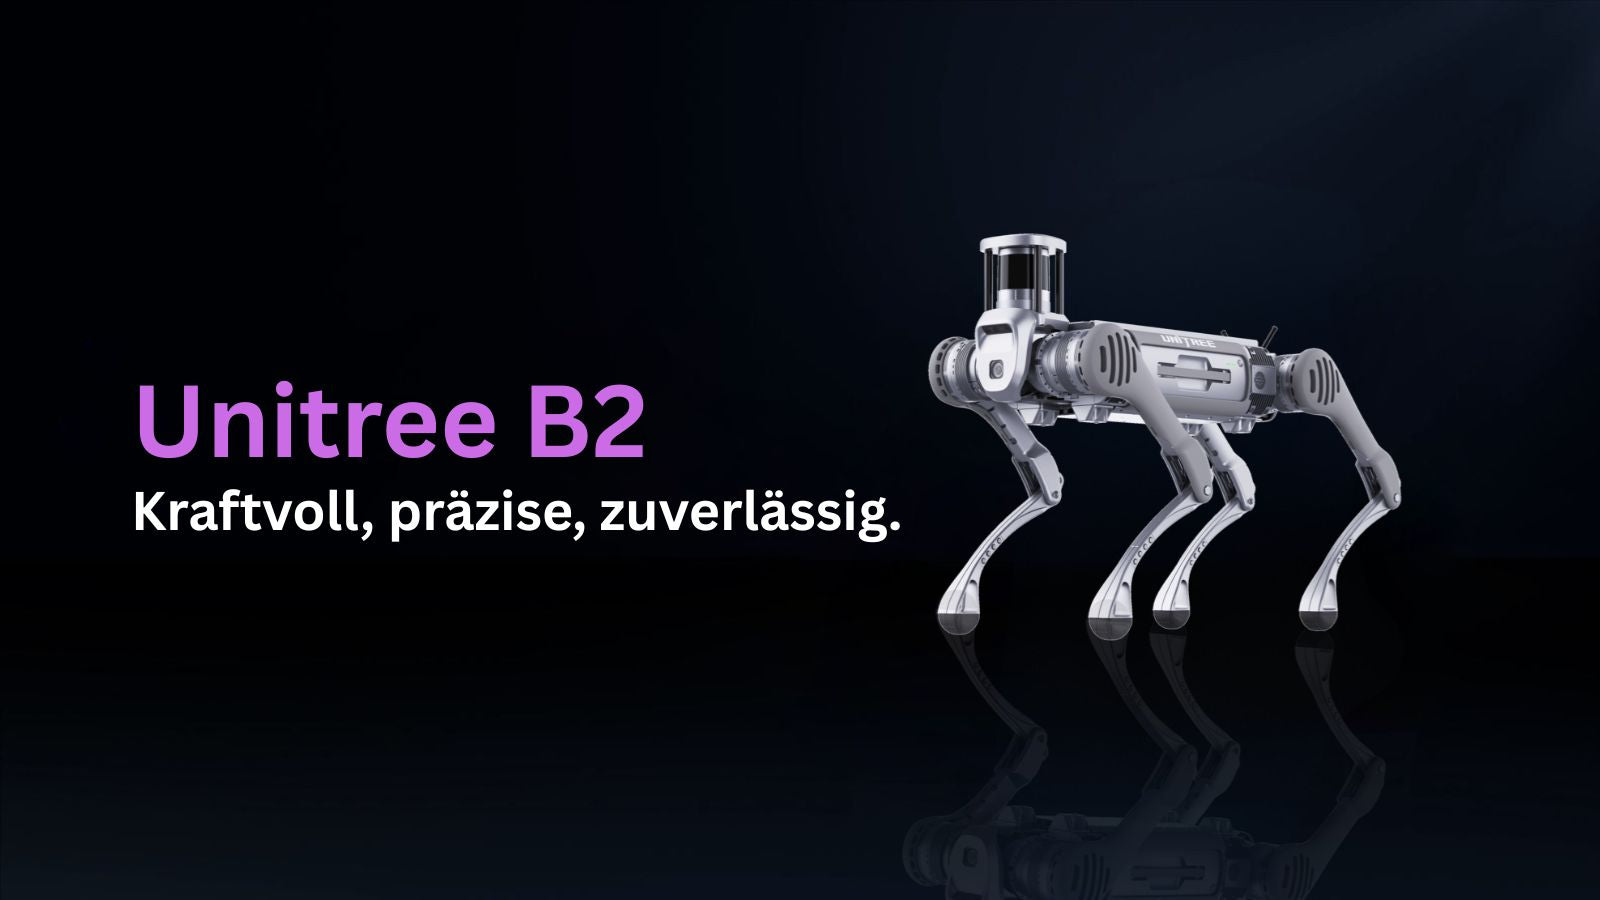
Key Features


Robotics with precise AI control
The Unitree B2 is redefining mobile robotics. Equipped with state-of-the-art 3D LiDAR sensing and a depth camera, it captures its surroundings in real time and reacts precisely to every movement. Its powerful joint actuators guarantee dynamic, stable movement even on challenging terrain. In combination with the optional Jetson Orin NX (100 TOPS), the B2 becomes the ideal platform for autonomous navigation, scientific applications, and industrial inspections.
Frequently Asked Questions
For which applications is the Unitree B2 robot dog suitable?
The Unitree B2 robot dog is suitable for industry, research, autonomous navigation, mobile inspection, security patrols, outdoor operations, robotics development, and AI-supported test environments. Terra Robotics specifically positions the Unitree B2 for companies and research teams that require a robust quadrupedal robot for real-world environments, uneven terrain, and demanding mobile robotics projects.
What is the Unitree B2?
The Unitree B2 is a quadrupedal robotic dog from Unitree designed for professional robotics, industrial, and research applications. It combines stable quadruped mobility, 3D LiDAR sensing, a depth camera, SLAM navigation, obstacle detection, and optional AI computing power to enable autonomous movement and mobile data collection in complex environments.
What distinguishes the Unitree B2 from smaller robot dogs like the Unitree Go2?
The Unitree B2 is designed more for industrial and professional use cases than smaller robotic dogs like the Unitree Go2. It focuses on robust mechanics, high-performance joint actuators, long operating times, advanced sensor technology, modular expandability, and its use as a platform for industrial inspection, research, AI navigation, and autonomous robotics applications.
Which versions of the Unitree B2 does Terra Robotics offer?
Terra Robotics offers the Unitree B2 in several versions, including the B2 Standard and an advanced 3D LiDAR configuration, the B2 Plus with Mid-360 LiDAR. The standard version is suitable for mobile robotics, development, and general inspection scenarios, while the advanced LiDAR version is particularly attractive for more detailed environmental perception, research, mapping, and autonomous navigation.
Why is the Unitree B2 interesting for industrial inspections?
The Unitree B2 is of interest for industrial inspections because it can autonomously support defined routes through warehouses, outdoor areas, technical facilities, or hard-to-reach operational areas. Thanks to 3D LiDAR, a depth camera, a SLAM system, and obstacle detection, the robot dog can map environments, detect obstacles, and enable mobile data collection for recurring inspection patrols.
Which sensors does the Unitree B2 use for navigation and environmental perception?
According to Terra Robotics, the Unitree B2 utilizes 3D LiDAR sensors, a depth camera, IMU sensors, and, depending on the variant, advanced LiDAR configurations such as the Mid-360 or Hesai XT16. This sensor suite supports real-time environmental perception, SLAM mapping, obstacle detection, autonomous path planning, and precise navigation in laboratories, industrial environments, and outdoor scenarios.
Can the Unitree B2 be used for research, AI, and secondary development?
Yes, the Unitree B2 is designed as an open platform for research, robotics development, and AI integration. Through SDKs, ROS interfaces, and API access, custom sensors, controllers, motion logic, and AI applications can be integrated. This makes the robot dog suitable for universities, laboratories, start-ups, and industrial development teams.
What role does the optional Jetson Orin NX module play in the Unitree B2?
The optional Jetson Orin NX module with 100 TOPS of computing power makes the Unitree B2 particularly interesting for AI navigation, sensor fusion, edge inference, autonomous decision-making logic, and industrial robotics projects. Development teams can use it to test perception models, real-time data processing, and AI-powered control directly on the mobile robot platform.
What prerequisites should be checked before using the Unitree B2?
Before deploying the Unitree B2, the target application, safety concept, operating environment, ground conditions, inclines, wireless coverage, data protection requirements, sensor needs, development resources, training requirements, maintenance, charging location, and potential accessory or computing modules should be assessed. Terra Robotics can provide support in planning the robot dog appropriately for industry, research, or inspection purposes.
Can the Unitree B2 be purchased, leased, or requested as a project solution from Terra Robotics?
The Unitree B2 can be purchased, leased, or requested as a custom project solution from Terra Robotics. Purchase is suitable for companies, universities, and research institutions that wish to use the robot dog on a permanent basis. Leasing offers predictable monthly costs, while a project request is particularly useful for training, safety concepts, accessory planning, AI integration, inspection routes, ROS workflows, or multiple robotics systems.
Unitree B2-W Robot Dog | industrial wheeled-legged robot for inspection, research, and demanding outdoor operations
The Unitree B2-W robotic dog is a highly advanced industrial quadruped robot with a wheel-leg hybrid drive for companies, research institutions, and organizations looking to deploy mobile robotics in demanding environments. It combines the all-terrain capability of a four-legged walking robot with the efficiency and speed of a wheel-based mobile robot. This makes the B2-W particularly suitable for inspection, security patrols, infrastructure checks, research, development, mapping, logistics monitoring, energy plants, industrial sites, construction sites, and hard-to-reach areas.
Unlike classic robotic dogs, the Unitree B2-W does not just move on legs but also uses wheels on its feet. This hybrid structure enables fast and energy-efficient movement on flat surfaces as well as precise control on uneven terrain. On paved paths, warehouse floors, or factory roads, the robot can roll to cover longer distances more efficiently. In more complex environments, it can use its leg mechanics to manage obstacles, inclines, stairs, or irregular surfaces with greater control.
This makes the Unitree B2-W not a simple demonstration platform, but a professional industrial quadruped for real-world application scenarios. It was developed for applications where classic wheel robots reach their limits and purely walking robots are less efficient over longer distances. It is precisely this combination that makes it particularly interesting for companies that want to regularly inspect, document, or autonomously traverse large areas, varying surfaces, or difficult-to-access areas.
Why the Unitree B2-W is compelling in industry and research
Many companies face the challenge of regularly monitoring large or difficult-to-access areas. These include energy plants, industrial sites, outdoor warehouse areas, construction sites, tunnels, factory premises, technical facilities, infrastructure corridors, or security zones. Manual inspections are time-consuming, physically demanding, and, depending on the environment, associated with risks. Classic mobile robots often fail to perform reliably on uneven terrain, stairs, gravel, ramps, or obstacles.
The Unitree B2-W addresses exactly this point. It combines high mobility, a robust design, and long range with an open, developer-friendly platform. Companies can use the robot for inspection routes, as a sensor carrier, for mobile data collection, mapping projects, or autonomous patrols. Research teams can use it for motion algorithms, navigation, AI applications, sensor fusion, or field tests.
The biggest advantage lies in the combination of efficiency and terrain capability. The wheel mode allows for rapid movement over longer distances. The leg architecture ensures that the robot is not limited to perfectly flat surfaces. As a result, the B2-W can be used in scenarios where various surfaces occur within the same mission: asphalt, concrete, gravel, grass, ramps, stairs, industrial floors, or uneven terrain.
Wheel-leg hybrid drive for maximum agility
The central feature of the Unitree B2-W is its wheel-leg hybrid drive. Each leg is equipped with a wheel, allowing the robot to roll efficiently or work in a controlled manner using its leg mechanics, depending on the environment. On flat surfaces, the wheel mode enables high speed and energy-efficient locomotion. On more complex surfaces, the leg mechanics support stability, balance, and obstacle traversal.
This combination is particularly valuable for industrial sites. Many locations do not consist of a uniform floor profile. A robot may need to drive through a hall first, then roll along a factory road, subsequently navigate a ramp, and then maneuver in a controlled manner on uneven ground. The B2-W is designed precisely for such mixed environments.
The wheels have a diameter of about 225 mm and are designed for dynamic movements. In combination with the high-performance joints, this creates a platform that can support both fast long-distance travel and precise maneuvers. For operators, this means the robot can efficiently cover ground in suitable areas while simultaneously managing more complex passages in a controlled manner.
Speed, range, and endurance for long missions
The Unitree B2-W is designed for high mobility and long mission distances. In special configurations, the robot reaches a maximum speed of up to 15 km/h. The maximum range is up to 25 km with a 40 kg load and about 30 km without a load. These values demonstrate the system's potential for long inspection routes, patrol missions, or expansive industrial areas.
For practical planning, it is important to note: such values always depend on configuration, terrain, load, speed, environment, temperature, driving profile, and safety limits. In real projects, the robot is often not operated at maximum speed continuously. Instead, speed, range, and driving behavior are adapted to the safety concept, terrain, sensor technology, and the specific task.
For companies with large areas in particular, range is an important factor. Factory premises, energy plants, logistics locations, or outdoor areas can require long distances. The B2-W can be a powerful platform here to automate recurring inspection trips or enable data collection over larger distances. This requires clean route planning, suitable communication, defined safety areas, and a clear operational strategy.
High payload for sensors, accessories, and industrial applications
The Unitree B2-W offers a high payload capacity for professional applications. In walking mode, it can carry loads of over 40 kg; in a standing position, significantly higher static loads are possible. This makes it suitable as a mobile platform for sensors, cameras, LiDAR systems, measuring instruments, edge computing units, or project-specific attachments.
For industrial inspections, this load capacity is particularly relevant. The robot can be equipped with thermal imaging cameras, 3D LiDAR, gas cameras, optical cameras, communication modules, or other sensors, provided these are integrated technically and mechanically in a suitable manner. This allows the B2-W to be adapted to different tasks: plant monitoring, thermography, security patrols, mapping, object inspection, research, or mobile data collection.
The specific payload should always be planned on a project-specific basis. Weight, center of gravity, mounting, power supply, cable management, and sensor protection influence stability, battery life, and operational behavior. For professional projects, it is therefore recommended to use clean technical integration rather than improvised attachments.
Robust construction with IP67 protection class
The Unitree B2-W is developed for demanding operating conditions. Its design is laid out for industrial and outdoor-oriented scenarios. The IP67 protection class supports use in dusty and humid environments. In addition, the robot is designed for a wide temperature range of approximately −20 °C to +55 °C. This makes it suitable for environments where simple indoor robots cannot be used reliably.
Typical areas of application include construction sites, energy plants, outdoor areas of logistics sites, industrial premises, tunnels, technical facilities, factory grounds, or research test fields. Dust, humidity, temperature fluctuations, uneven floors, or changing lighting conditions can occur there. The B2-W provides the mechanical and technical foundation to better cover such operational profiles.
Despite its robust design, use should not be broadly understood as risk-free. Heavy rain, extreme contamination, chemical exposure, deep mud, unstable ground, or hazardous plant areas must be assessed separately. For professional applications, operational limits, maintenance, cleaning, and safety requirements should be clearly defined.
Stairs, inclines, and rough terrain
An important advantage of the Unitree B2-W is its ability to handle different terrain structures. It can master stairs, inclines, barricades, and various ground types, provided the conditions are within the technical operational limits. The platform is designed to support movement on grass, stone, gravel, ramps, and rougher surfaces.
The robot can continuously handle stairs in the range of about 20 to 25 cm and overcome steps or obstacles of up to about 40 cm in the forward direction. Inclines of more than 45° are also stated as a capability by the manufacturer. In practice, such values should always be checked with regard to safety, ground surface, load, weather, and the actual environment.
For inspection and security applications, this all-terrain capability is particularly valuable. A robot that only functions on flat surfaces is too limited for many industrial and outdoor areas. The B2-W, on the other hand, can also be used where paths are not fully standardized. This is precisely what makes it interesting for infrastructure, energy, construction, research, and demanding mobile robotics projects.
Sensor technology, 3D LiDAR, and autonomous navigation
The Unitree B2-W can be equipped with 3D LiDAR, depth cameras, and IMU sensor fusion. This sensor suite supports orientation, obstacle detection, mapping, and autonomous navigation. In the variant with 32-line LiDAR, the robot can capture particularly detailed 3D environmental data, which is relevant for mapping, inspection, and autonomous navigation in complex environments.
For companies, this is especially important if the robot is to be used not only via remote control but as a mobile data platform. During inspections, sensor data can be collected, environments documented, and recurring routes analyzed. In research and development, proprietary algorithms for perception, localization, path planning, or object recognition can be tested.
However, autonomy should be viewed realistically. Many advanced functions depend on configuration, software, sensor suite, environment, and, if applicable, additional development. Not every autonomous application is immediately available fully out of the box. For professional projects, requirements, degree of autonomy, safety concepts, and integration should be clearly defined in advance.
Edge computing, ROS, and development platform
The Unitree B2-W is not just a finished robotic dog, but also an open development platform for demanding robotics projects. As standard, the platform can work with Intel computing units; optionally, more powerful configurations with Jetson Orin NX for AI and edge computing applications are possible. This makes the B2-W particularly interesting for research, industrial development, universities, automation projects, and AI applications.
By supporting modern development environments and ROS-based workflows, the robot can be integrated into proprietary software projects. Research teams can develop algorithms for navigation, mapping, sensor fusion, autonomous inspection, motion control, or human-robot interaction. Companies can build project-specific applications, for instance for data collection, monitoring, route planning, or the integration of external sensors.
This openness is a significant advantage, but it also carries responsibility. Anyone using the B2-W as a development platform should possess the corresponding technical competence. Proprietary extensions must be implemented cleanly in terms of mechanics, electronics, and software. Especially with autonomous missions in real environments, tests, safety concepts, and clear operational limits are indispensable.
Areas of application: Inspection, security, construction, energy, and research
Construction sites and infrastructure control
On construction sites, the Unitree B2-W can be used for documentation, site walks, and data collection. It can manage uneven paths, changing surfaces, and larger areas, making it suitable for construction progress monitoring, site surveying, and recurring inspection routes.
Energy plants and technical infrastructure
In energy plants, substations, power plants, or technical operating areas, the robot can support inspection routes. With suitable sensor technology, visual data, thermal images, or environmental information can be captured. This can relieve employees during recurring inspections.
Factory premises and security patrols
On large factory premises, the B2-W can be used for patrols, visual checks, or mobile surveillance. Particularly in the case of long distances, outdoor areas, or hard-to-access zones, it can help make regular rounds more structured and better documented.
Outdoor warehouse areas and logistics monitoring
In logistics and warehouse environments, the robot can monitor outdoor areas, access roads, storage spaces, or hard-to-access zones. The combination of wheels, legs, and long range makes it particularly interesting for expansive sites.
Tunnels, special inspections, and critical infrastructure
Tunnels, underpasses, pipe systems, or special technical areas place high demands on mobility, sensor technology, and operational safety. The Unitree B2-W can serve here as a mobile platform for exploration, documentation, or inspection if the environment and safety concept are suitable.
Research, development, and education
For universities, research institutions, and development departments, the B2-W is a powerful platform for mobile robotics. It is suitable for projects involving autonomous navigation, AI, sensor fusion, motion control, mapping, edge computing, and terrain mobility.
Safety, operation, and responsible use
The Unitree B2-W is a high-performance mobile robot platform. It is precisely for this reason that responsible operation is decisive. Before deployment, areas, routes, human traffic, emergency processes, communication links, safety zones, and operational limits should be precisely defined. Especially with high speeds, heavy payloads, or autonomous functions, careful planning is essential.
The robot should only be operated by trained personnel. Employees must know how the B2-W is started, stopped, charged, transported, maintained, and secured in an emergency. The use of sensor technology, cameras, or data transmission should also be planned in compliance with data protection and security regulations.
For public or semi-public areas, additional requirements apply. There, people, vehicles, animals, obstacles, and unpredictable situations must be given special consideration. The B2-W can be a strong platform for inspection and automation, but should always be operated within the framework of a professional safety and operational concept.
Economic viability and project assessment
The economic viability of the Unitree B2-W does not arise from a single key figure, but from the specific use case. The robot is particularly useful where there is a need for regular inspections, long distances, difficult terrain, safety risks, or a high documentation requirement. If employees have to cover long distances daily or check dangerous areas, a mobile robot platform can be strategically valuable.
For a well-founded assessment, companies should check which routes are checked regularly, how often inspections take place, what data should be collected, what risks exist for employees, and what sensor technology is required. Integration, maintenance, training, communication infrastructure, and software development should also be considered.
The B2-W is particularly interesting for organizations that view robotics not just as a single device, but as part of a larger automation strategy. In combination with mapping, AI analysis, teleoperation, sensors, or autonomous routes, the robot can become a scalable platform for inspection, monitoring, and research.
Service, implementation, and introduction with Terra-Robotics
An industrial robotic dog only unfolds its benefits when the application scenario, technology, and operational concept align. Before introduction, goals, routes, terrain, sensors, communication links, charging schedules, safety requirements, and operational processes should be defined. The question of whether the robot should be used primarily via remote control, semi-autonomously, or as a development platform is also decisive.
Terra-Robotics provides support with consulting, project planning, introduction, training, and technical implementation. As a result, the Unitree B2-W is not just viewed as hardware, but as part of a professional robotics project. Especially for industrial, research, and outdoor applications, this planning is important so that the robot can be deployed reliably, safely, and meaningfully.
A sensible start is made with a clearly defined use case: for example, a regular inspection trip on a factory site, data collection in an outdoor area, a research test on defined terrain, or the mobile monitoring of an infrastructure area. After the first deployments, sensors, routes, software, and processes can be further optimized.
Conclusion: Unitree B2-W as a high-performance robotic dog for demanding industrial applications
The Unitree B2-W robotic dog is a professional mobile robotics platform for companies and research institutions that require high mobility, a robust design, and long range in demanding environments. Its strengths lie in the wheel-leg hybrid drive, high speed, long range, high payload, IP67 protection class, 3D LiDAR option, edge computing, ROS support, and flexible expandability.
The B2-W is particularly suitable for industrial inspection, security patrols, construction sites, energy plants, outdoor warehouse areas, tunnels, critical infrastructure, research, and mobile robotics development. It is not a toy and not a simple consumer robot, but a powerful industrial quadruped for professional projects. Properly planned and responsibly deployed, the Unitree B2-W can open up new possibilities for autonomous inspection, terrain mobility, data collection, and robot-assisted automation.
Now continue with the Unitree B2 robotic dog
https://terra-robotics.de/products/unitree-b2-roboterhund
Unitree B2 robotic dog | industrial quadruped robot for inspection, research, and demanding missions
The Unitree B2 robotic dog is a professional industrial quadruped robot for companies, research institutions, and organizations that want to deploy mobile robotics in demanding environments. It was developed for applications where traditional wheeled robots reach their limits and human inspections are time-consuming, physically demanding, or difficult to schedule. This makes the Unitree B2 particularly suitable for industrial inspection, research, development, security patrols, infrastructure control, energy facilities, construction sites, factory premises, logistics areas, and special technical applications.
Unlike smaller robotic dogs, the Unitree B2 is clearly designed for professional industrial and research applications. It combines high mobility, powerful joint actuators, a robust design, long runtime, high payload capacity, and expandable sensor technology in a high-performance platform. As a result, it can be used not only as a remote-controlled robotic dog but also as a mobile base for autonomous navigation, data acquisition, AI development, mapping, inspection, and custom robotics projects.
The Unitree B2 is neither a toy nor a mere demonstration device. It is an industrial robot platform for demanding operational profiles. Its strengths lie in movement on uneven terrain, overcoming obstacles, long deployment times, and the integration of additional sensors or computing units. For companies that are thinking beyond traditional indoor robots for mobile automation, the B2 offers a strong foundation for professional robotics projects.
Why the Unitree B2 is convincing in industry and research
Many companies need to regularly inspect large or hard-to-reach areas. This includes industrial facilities, energy infrastructure, outdoor areas, warehouse spaces, construction sites, tunnels, technical operating areas, or expansive factory premises. Manual patrols tie up personnel, take a long time, and can involve risks depending on the environment. At the same time, traditional mobile robots often rely on smooth, level surfaces and have limited ability to reach stairs, gravel, ramps, or complex terrain sections.
The Unitree B2 closes exactly this gap. As a four-legged robot, it can move much more flexibly through different environments than many wheel-based platforms. It can walk stably on level surfaces, handle uneven terrain, climb stairs, cross obstacles, and be used in more complex areas. This makes it suitable for tasks where mobility, stability, and terrain adaptability are crucial.
For research institutions, the B2 is particularly interesting because it can be used as an open and expandable platform. Proprietary algorithms, sensors, AI models, navigation systems, or control logic can be integrated on a project-specific basis. For companies, it is interesting when recurring inspection or control tasks are to be automated, documented, or carried out semi-autonomously in the future.
High mobility on challenging terrain
The Unitree B2 was developed for versatile terrain adaptation. It can be used on various surfaces, including concrete, asphalt, warehouse floors, gravel, grass, stone, ramps, and uneven terrain. Its ability to handle stairs, inclines, and obstacles is particularly relevant. This opens up operational possibilities that would not be realistic with traditional automated guided vehicles or simple indoor robots.
The platform can continuously handle stairs in the range of approximately 20 to 25 cm and, in a forward direction, also overcome higher steps or obstacles, provided that the surface, load, environment, and safety conditions are suitable. Steep inclines are also technically possible. In practice, however, such performance values should always be checked on a project-specific basis. Ground conditions, moisture, dirt, load, center of gravity, and the safety concept influence real-world operation.
Especially in industry and infrastructure, this mobility is a major advantage. A robot that only works on perfect floors is too restricted for many real-world locations. The Unitree B2, by contrast, is designed for mixed environments and can be deployed where paths are not always level, clear, or standardized.
Performance, speed, and endurance
The Unitree B2 is designed for high motion performance. Under special configurations, speeds of over 6 m/s are possible. In professional applications, however, speed is usually deliberately adapted to the environment, safety concept, and operational task. For inspection, mapping, or security patrols, it is not maximum speed that is decisive, but stable, controlled, and repeatable movement.
The B2 is also designed for long missions in terms of endurance. The battery capacity is 45 Ah or around 2250 Wh. Depending on load, terrain, speed, temperature, sensor technology, and usage profile, runtimes in the range of several hours are possible. Without a load, the robot can run continuously for over 5 hours; with a 20 kg load, more than 4 hours are possible. The actual runtime always depends on the specific project and the mode of operation.
For operators, realistic mission planning is therefore important. In some projects, a few inspection trips per day are sufficient. In other scenarios, fixed charging windows, swappable batteries, docking solutions, or multiple robots make sense. The B2 provides the technical basis for long missions but should always be planned appropriately for the respective route, sensor suite, and task.
High payload capacity for sensor technology and custom attachments
An important advantage of the Unitree B2 is its high payload capacity. The robot can carry loads of over 40 kg during operation. Significantly higher static loads are possible while standing. This makes it suitable as a mobile platform for additional sensors, cameras, LiDAR systems, thermal imaging technology, measuring devices, communication modules, edge computing hardware, or custom attachments.
For industrial inspections, this load capacity is particularly relevant. Depending on the project, the B2 can be equipped with a thermal imaging camera, 3D LiDAR, optical camera, gas sensors, acoustic sensors, or other measurement systems. This allows the robot to be adapted to very different tasks: plant monitoring, security patrols, mapping, environmental capture, construction progress documentation, research, or mobile data collection.
The specific integration should always be planned professionally. Weight, center of gravity, mounting, power supply, cable management, and protection of the sensors influence stability, runtime, and safety. For reliable results, a clean technical implementation is recommended rather than improvised structures.
Robust design with IP67 protection
The Unitree B2 is developed for demanding environments. The IP67 protection class supports use in dusty and humid environments. In addition, the robot is designed for a wide temperature range of approximately −20 °C to +55 °C. This makes it significantly better suited for industrial and outdoor-related applications than many simple indoor robots.
Typical areas of application include construction sites, technical facilities, energy infrastructure, factory premises, warehouse outdoor areas, tunnels, test fields, research areas, and industrial inspection environments. There, dust, moisture, temperature fluctuations, uneven floors, and changing lighting conditions can occur. The B2 offers the mechanical and technical foundation to support such operational profiles.
Despite its robust design, its use should not be considered limitless across the board. Heavy rain, deep mud, aggressive chemicals, extreme contamination, unstable ground, or hazardous plant areas must be assessed separately. For professional applications, operational limits, cleaning routines, maintenance, and safety requirements should be clearly defined.
Sensors, environmental capture, and autonomous navigation
The Unitree B2 can be equipped with modern sensor technology for environmental capture and navigation. Depending on the configuration, this includes 3D LiDAR, depth cameras, optical cameras, and IMU sensors. These sensors support perception, obstacle detection, mapping, and orientation in more complex environments.
For inspection and research projects, this sensor suite is a central component. The robot can collect environmental data, map areas, detect obstacles, and serve as a mobile data platform. In combination with additional software, routes can be planned, sensor data can be evaluated, and recurring inspection runs can be established.
Autonomy should, however, be viewed realistically. Depending on the configuration, software status, sensors, and environment, different degrees of autonomy can be achieved. Some functions require additional setup, development, or project integration. For professional applications, requirements, the safety concept, operating mode, and desired autonomy should therefore be clearly defined.
AI, edge computing, and development platform
The Unitree B2 is suitable not only as a finished robotic dog but also as a development platform for demanding robotics and AI projects. Depending on the equipment, powerful computing units can be integrated, including Intel-based systems and optional NVIDIA Jetson Orin NX. This makes the robot interesting for edge computing, AI evaluation, autonomous navigation, sensor fusion, and proprietary robotics applications.
Through interfaces, SDKs, ROS-based workflows, and API access, the B2 can be integrated into development projects. Research teams can test their own algorithms for navigation, motion control, mapping, object recognition, or human-robot interaction. Companies can build project-specific applications, for example, for inspection routes, mobile data collection, or the integration of external sensors.
This openness is a great advantage but requires technical know-how. Anyone using the B2 as a development platform should carefully plan mechanical, electrical, and software-side integrations. Especially for autonomous missions in real-world environments, tests, safety assessments, and clear operational limits are indispensable.
Areas of application: inspection, security, construction, energy, and research
Industrial inspection
In industrial facilities, the Unitree B2 can be used for recurring inspection patrols. With suitable sensors, it can capture visual data, thermal images, environmental data, or other readings. This can make inspection processes more structured, documentable, and scalable in the long term.
Energy facilities and technical infrastructure
In energy plants, substations, power plants, or technical operating areas, the B2 can monitor hard-to-reach areas and support regular inspections. Especially in large areas or where there is an increased need for security, a mobile robot platform can be a useful supplement to operations.
Construction sites and construction progress documentation
On construction sites, the robot can be used for data collection, visual documentation, site walks, or construction progress monitoring. Its off-road capability makes it interesting for environments that are too uneven or variable for traditional mobile robots.
Security patrols and factory premises
On large factory premises, the Unitree B2 can be used for patrols, visual inspections, or mobile surveillance. In combination with cameras or other sensors, it can support recurring control tasks and travel defined routes.
Tunnels, special areas, and critical infrastructure
Tunnels, underpasses, special technical areas, or hard-to-reach infrastructure place high demands on mobility and operational safety. The B2 can serve as a mobile platform for exploration, documentation, and inspection if the environment and safety concept are appropriate.
Research, development, and education
For universities, research institutions, and development departments, the Unitree B2 is a powerful platform for mobile robotics. It is suitable for projects involving autonomous navigation, AI, sensor fusion, motion control, mapping, terrain mobility, and human-robot interaction.
Differentiation from the Unitree B2-W
The Unitree B2 is the classic four-legged industrial quadruped without a permanently integrated wheel-leg drive. It is particularly strong when robust walking movement, terrain adaptation, stair-climbing ability, and an expandable robotics platform are the priority. The Unitree B2-W, on the other hand, combines legs with wheels, making it particularly efficient and fast when rolling on level surfaces.
Which variant is more sensible depends on the application. If the focus is on classic four-legged mobility, research, inspection, and terrain adaptation, the Unitree B2 is the appropriate platform. If the focus is on long distances on smooth or mixed surfaces with higher rolling efficiency, the B2-W may be the better choice. For many industrial projects, a precise application analysis is therefore worthwhile before selection.
Safety, operation, and responsible use
The Unitree B2 is a powerful mobile robot platform. Precisely for this reason, operation should be carefully planned. Before deployment, areas, routes, human traffic, obstacles, emergency processes, communication links, safety zones, and operating limits must be checked. Especially with high speed, heavy payload, or autonomous functions, a clear safety concept is decisive.
The robot should only be operated by trained persons. Operators must know how to start, stop, charge, transport, maintain, and secure the B2 in an emergency. Sensor technology, cameras, data transmission, and possible recordings should also be planned in compliance with data protection and security regulations.
The Unitree B2 is a civilian robotics platform and should be used exclusively for safe, legal, and responsible applications. Dangerous modifications, risky operational profiles, or unauthorized uses should be avoided. For professional projects, clear operating guidelines and thorough training are indispensable.
Economic efficiency and project evaluation
The economic efficiency of the Unitree B2 depends heavily on the specific use case. The robot is particularly useful where regular inspections, long distances, difficult terrain, high documentation requirements, or potential safety risks exist. If employees frequently cover long distances, check hard-to-reach areas, or need to collect recurring inspection data, a mobile robot platform can be strategically valuable.
For a sound assessment, companies should check which routes are regularly driven or walked, which data should be collected, how often inspections take place, what risks exist for employees, and what sensors are required. Training, maintenance, software development, charging infrastructure, communication network, and integration into existing systems should also be considered.
The B2 is particularly interesting for organizations that view robotics not just as a single device, but as part of a long-term automation strategy. In combination with AI evaluation, mapping, sensors, teleoperation, or autonomous routes, the robot can become a scalable platform for inspection, surveillance, and research.
Service, implementation, and introduction with Terra-Robotics
An industrial robotic dog only unfolds its utility when the deployment scenario, technology, and operating concept fit together. Before introduction, goals, routes, terrain, sensors, communication links, charging planning, safety requirements, and operating processes should be defined. The question of whether the robot should be used primarily via remote control, semi-autonomously, or as a development platform is also decisive.
Terra-Robotics provides support with consulting, project planning, introduction, training, and technical implementation. This means the Unitree B2 is not just viewed as hardware, but as part of a professional robotics project. Especially for industrial, research, and outdoor applications, this planning is important so that the robot can be used reliably, safely, and sensibly.
A sensible start is made with a clearly defined use case: for example, a regular inspection tour on a factory premise, data collection in an outdoor area, research tests on defined terrain, or mobile surveillance of an infrastructure area. After the first deployments, sensors, routes, software, and processes can be further optimized.
Conclusion: Unitree B2 as a powerful industrial robotic dog for professional applications
The Unitree B2 robotic dog is a powerful platform for companies, research institutions, and organizations that want to deploy mobile robotics in demanding environments. Its strengths lie in its robust four-legged architecture, high off-road capability, strong payload capacity, long runtime, IP67 protection class, expandable sensors, optional AI computing unit, and flexible development opportunities.
The B2 is particularly suitable for industrial inspection, security patrols, construction sites, energy facilities, warehouse outdoor areas, tunnels, critical infrastructure, research, and mobile robotics development. It is not a simple consumer robot, but a professional quadruped for demanding projects. Properly planned and responsibly deployed, the Unitree B2 can open up new possibilities for autonomous inspection, terrain mobility, data collection, and robot-assisted automation.