


Humanoid robotics
Human-like finger movements and flexible grasping patterns enable integration into humanoid robots for complex manipulation and handling tasks.
Linkerbot


Switch between the tabs to view content.
Human-like finger movements and flexible grasping patterns enable integration into humanoid robots for complex manipulation and handling tasks.

For grasping strategies, learning-based manipulation, and robotics research. The high level of mobility offers a powerful platform for practical AI experiments.

For flexible assembly, sorting, and handling processes involving varying objects. Differentiated finger movements enable precise gripping, aligning, and inserting.

For remote manipulation and the acquisition of real-world motion data. In combination with Linkerbot teleoperation solutions, complex hand movements can be transmitted and evaluated.

Different types of grippers allow for handling varying shapes, sizes, and surfaces – ideal for flexible handling and operating tasks.

For universities, research labs, and developers for practical work in robotics, control, grasp planning, sensor technology, and intelligent manipulation.
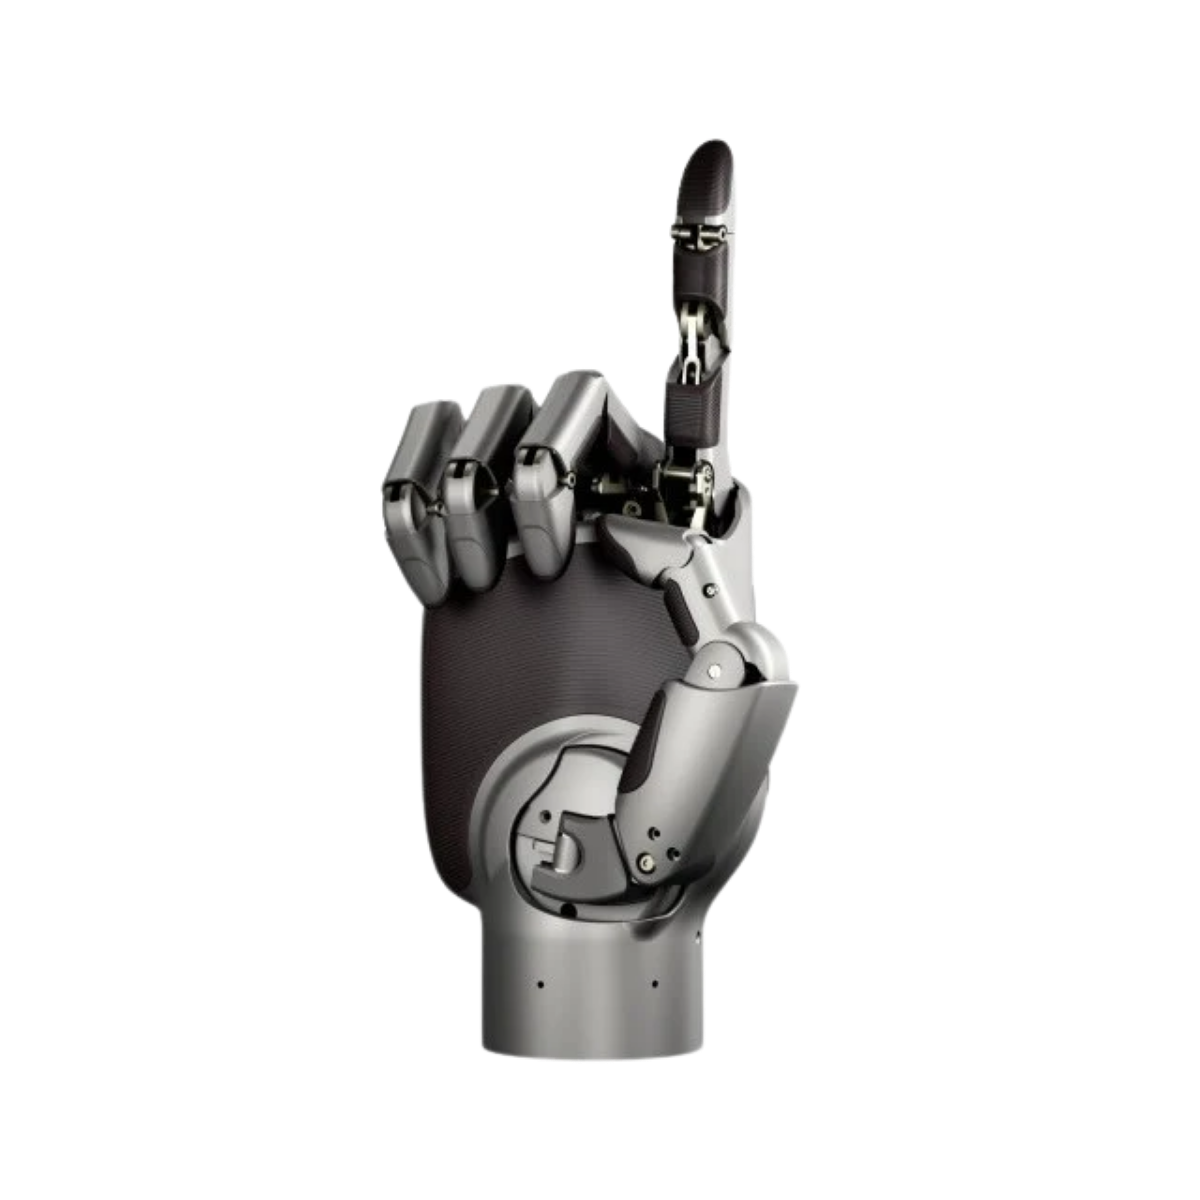
The Linker Hand L20 is a highly sophisticated bionic robotic hand with 21 joints and 16 active degrees of freedom, designed for the most demanding tasks in research, industrial automation, domestic assistance, and medicine. Utilizing a linkage drive and custom-developed motors, it simulates the natural grasping and manipulation behavior of the human hand with extreme precision. The integration of multimodal sensor technology and advanced force-position control makes it an ideal interface for AI robotics.
Advantage for Professionals: With 16 active degrees of freedom and a 10 kg payload, the Linker Hand L20 sets new standards for human-like handling systems. Thanks to advanced visuo-tactile options, high grip force (100 N), and simple cloud and SDK connectivity, it is ideal for demanding AI training pipelines, industrial precision assembly, and advanced teleoperation setups.
Terra Robotics
https://terra-robotics.de/
mail@terra-robotics.de
Zeißstraße 10,
32584 Löhne
Germany

Precise gripping
Linkerbot robotic hands are designed for controlled gripping and manipulation tasks. Precise joint control and differentiated finger movements enable the secure gripping, holding, rotating, and positioning of a wide variety of objects – from small components to everyday items.

Flexible gripping movements
The multi-jointed five-finger kinematics enable versatile gripping patterns modeled on the human hand. Depending on the model, various active and passive degrees of freedom are available – for grasping, pincer grips, tool handling, and complex manipulation tasks.

Versatile gripping methods
Different types of grips expand the range of applications far beyond classic pick-and-place. Depending on the model, the Linker Hands can precisely pick up small objects, guide tools, or stably grasp and move larger items.

Flexible system integration
Linkerbot robotic hands can be integrated into humanoid platforms, robotic arms, and research setups. Depending on the model, interfaces such as CAN, RS485, CAN FD, or EtherCAT are available, enabling integration into various control and development environments.
Linkerbot provides technical documentation, user manuals, SDK resources, communication protocols, demo applications, as well as 3D models and fasteners for developers. This allows development and integration projects to be structured effectively.
Linkerbot provides graphical control and development tools for various Linker Hand models. Depending on the product, solutions for Windows and Ubuntu, among others, are available for testing functions and implementing development setups.
Voltage and power supply requirements vary by model. Many Linker Hands work with industrial 24 V systems or an extended voltage range up to 48 V. For specific design requirements, the technical data for the selected model should always be consulted.
Several Linker Hand models achieve a repeat positioning accuracy of approximately ±0.20 mm. However, the actual precision depends on the model, configuration, control, and specific application.
Movement speed is model-dependent. While some models are designed for powerful and controlled movements, high-speed models achieve particularly short opening and closing times. The Linker Hand L30, for example, requires only about 0.2 seconds.
Gripping force describes the force with which fingers or the entire hand can grip an object. Maximum load, on the other hand, describes the load-bearing capacity of the system under defined conditions. Both values must therefore not be directly equated with one another.
The energy demand depends on the model, movement, and load. Linkerbot specifies values for quiescent current, average current during unloaded movement, as well as maximum power consumption or output, depending on the robotic hand. These data should be taken into account when dimensioning the overall system.
This depends on the specific model and application profile. Individual Linker Hands are specifically designed for high industrial loads. For applications with long operating times, high forces, or a very large number of movement cycles, the model should therefore be selected to match the planned utilization.
Yes. Product and connection element models are available for development projects in the Linkerbot Developer Center. This allows mechanical installation situations and adapters to be taken into account during the design phase.
Depending on the left-handed model, different housing colors and configurations are available. The available options differ between product series and should therefore be checked directly for the respective model.
Linkerbot develops dexterous robotic hands for demanding manipulation tasks in humanoid robotics, research, and industrial automation. Unlike classic two-finger grippers, five-fingered robotic hands enable significantly more versatile gripping movements. Objects can not only be picked up and put down, but specifically held, rotated, aligned, or manipulated with various grip patterns.
This makes Linker Hands particularly suitable for applications where object shapes or tasks change and a rigid gripper reaches its limits. The human-like kinematics also create an important foundation for modern humanoid robots, which are increasingly being used for research, development, and industrial pilot projects.
The Linkerbot portfolio includes various robotic hands with different technical focuses. Models such as Linker Hand O6, L6, L10, L20, O30, and L30 differ in terms of, among other things, agility, the number of active and passive degrees of freedom, weight, gripping force, speed, and drive technology.
As a result, the same hardware does not have to be used for every application. Compact robotic hands, for example, are suitable for systems where a low moving mass is important. Highly agile models, on the other hand, offer additional possibilities for complex finger positions and demanding manipulation tasks.
Linkerbot also pursues different technological approaches. Depending on the model, linkage drives, cable drives, or direct drives are used. This allows robotic hands to be selected more specifically based on dynamics, precision, and integration requirements.
A high-performance hand is one of the most important components of a humanoid robot. Movement and perception alone are not enough if a system is to actively interact with its environment. Only suitable hands enable, for example, the grasping of tools, the operation of controls, the sorting of objects, or the positioning of components.
Dexterous hands are therefore particularly relevant for Embodied AI. In this context, AI systems learn not only from digital information but interact with the real environment via sensors and actuators. A multi-fingered robotic hand significantly expands the available action possibilities and enables more complex training and manipulation scenarios.
For companies and research institutions that wish to consider complete platforms, Terra Robotics offers a wide range of humanoid robots for industry and research in addition to robotic hands.
Linkerbot robotic hands can also be used as end-effectors in industrial applications. They are particularly interesting where different workpieces are handled or different types of grips are required within a process.
Possible applications range from picking up small components and aligning and inserting parts to tool handling. The individually or differentially movable fingers enable tasks that would only be possible to a limited extent with classic parallel grippers or would require multiple specialized grippers.
Whether a dexterous robotic hand is economically viable depends on the specific process. Parts variety, required precision, cycle time, object geometry, and integration effort should be considered together. Further solutions for industrial manipulation tasks can be found in the Assembly & Handling section.
Another focus of the Linkerbot ecosystem is the connection of robotic hardware with teleoperation and motion data acquisition. Human movements can serve as a basis for transferring complex manipulation sequences to robotic systems or for collecting training data for learning-based models.
This is particularly interesting for Robot Learning, Imitation Learning, and research projects. Instead of programming every single movement exclusively by hand, demonstration data can be used to develop new behaviors and gripping strategies.
For this purpose, Linkerbot supplements its robotic hands with further hardware and development solutions. This creates an ecosystem that supports not only the actual end-effector but also research and development surrounding dexterous manipulation.
For universities, research laboratories, and development departments, robotic hands are also of interest as open development platforms. For this purpose, Linkerbot provides technical documentation, communication protocols, development resources, and 3D data depending on the product.
As a result, custom control algorithms, gripping strategies, or AI applications can be developed and tested. At the same time, mechanical adapters and installation situations can be taken into account during the design phase.
In addition to professional research platforms, Terra Robotics offers other solutions specifically for teaching, training, and robotics development in the Educational Robot section.
The robotic hand with the most degrees of freedom is not automatically the best solution. What is decisive is which movements the specific application actually requires.
Important selection criteria include active degrees of freedom, passive degrees of freedom, gripping force, weight, speed, dimensions, communication interface, and sensor technology. The existing robot platform also plays an important role. Weight and size, for example, influence the payload and dynamics of a robotic arm.
In research applications, on the other hand, maximum agility, development access, and data acquisition may be more important than particularly high gripping force. For industrial processes, however, repeatability, reliability, and integration into existing control systems are more in the foreground.
Anyone wanting to buy a Linkerbot robotic hand should therefore not exclusively compare individual data sheet values. The interaction between the robotic hand, robot platform, control system, and planned application is crucial.
Terra Robotics provides support in selecting the appropriate Linker Hand and with the technical coordination for research, humanoid robotics, and industrial applications. Together, requirements such as agility, gripping force, weight, interfaces, and desired sensor technology can be evaluated.
You can find an overview of the manufacturer and the various solutions on our Linkerbot manufacturer page. If a specific project is already being planned, you can coordinate your requirements with us directly via our robotics consultation.